RP1 humanoid
An open-source humanoid that walks, waves and dances in the world.
01 / What it was
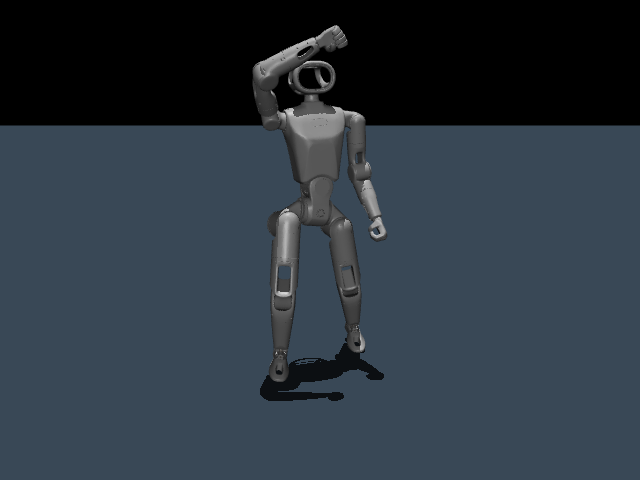
RoboParty publishes the RP1, an open-source humanoid robot, with its description files and pretrained policies. We used the same pattern as the duck to bring its 24-joint variant into the world.
It was spawned and danced on the stream early on 28 October: "Now it's truly online."
02 / How it worked
- MuJoCo with a 50 Hz policy, using RoboParty's own policies for walking, a wave learned from a motion clip, and a dance.
- The hardware joint gains came first; with them the robot stood and turned but did not walk forward. The gains from RoboParty's training setup fixed it.
- Measured: walking at 0.395 m/s, turns of about 86 degrees in 2.6 s, and two 10-minute runs of random commands with no falls.
- One sim metre is one block, so it stands about 1.5 blocks tall.
- A persona with its own voice; while it talks, a small sway is added to the standing policy.
03 / What we saw
Unlike the duck, it cannot see Minecraft blocks: it walked through walls in a demo. It would not follow on voice command, and there is no get-up policy, so every fall ends in a reset.
04 / Where it led
It raised the question a friend asked on the call: can a robot like this do real work, "like hold something"?
Sources
- Stream analysis. stream transcript analysis, 28 Oct 2026
Now it's truly online.
- Stream analysis. stream transcript analysis, 28 Oct 2026
rp1 follow me and it's not working but maybe the ducks
- Simulation notes (local, not published). RP1 simulation README, Oct 2026
Only a flat floor; the robot can't see Minecraft blocks.
- Robots paper, sources (RoboParty's RP1 description files are credited there). /research/robots/
RoboParty publishes the RP1's description files [S8] and deploy code with pretrained policies [S9].